

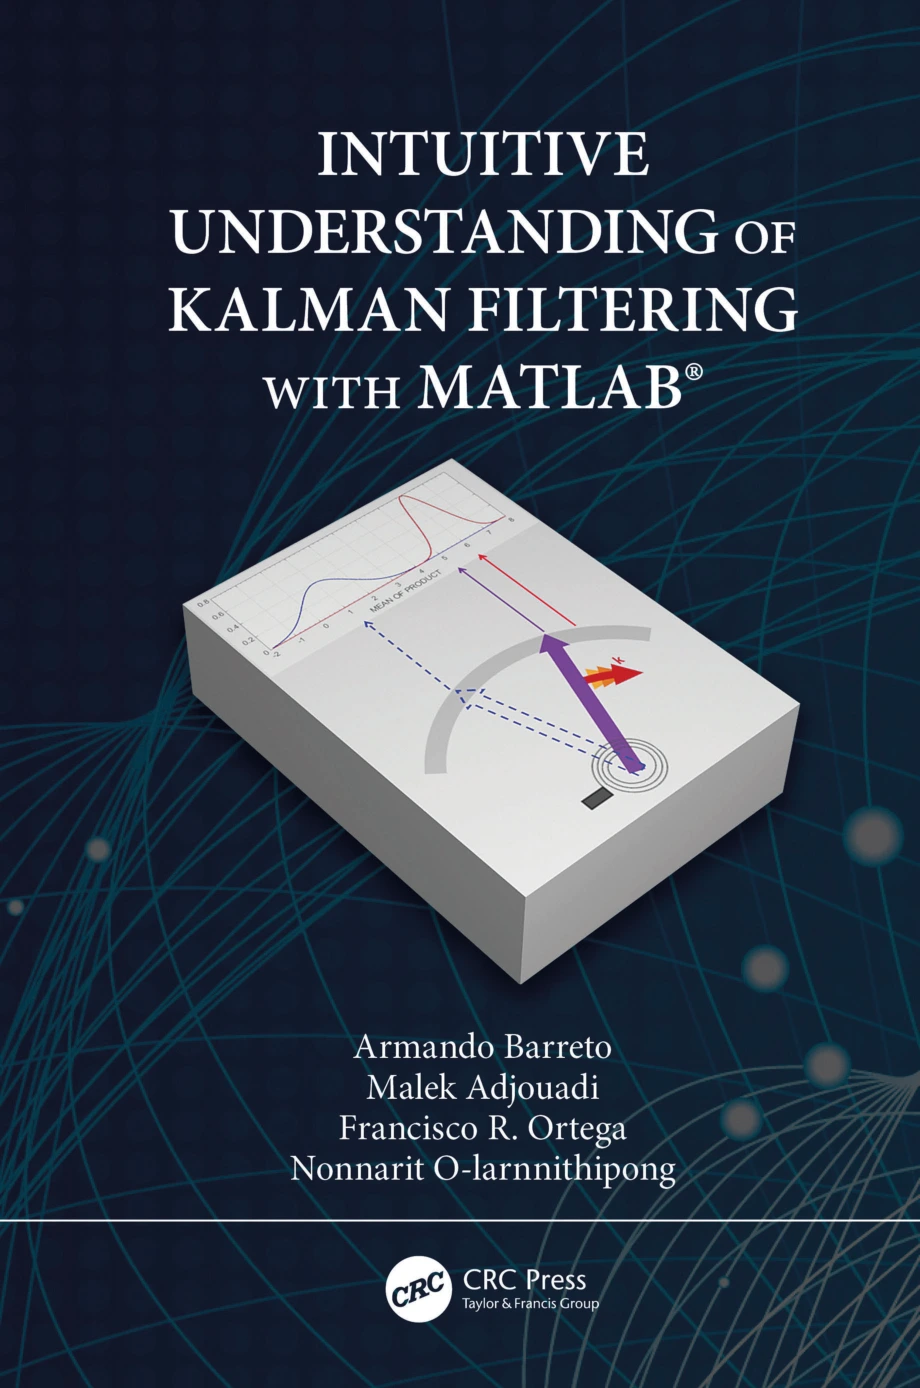
Intuitive Understanding of Kalman Filtering with MATLAB®
Original price was: $46.75.$23.38Current price is: $23.38.

Armando Barreto
Product Specs:
- File Type: PDF
- File Size: 8.1 MB
- Book Language: English
- Total Page Count: 248
- Instant Download
Kalman filtering can seem abstract until its central problem becomes concrete: how should an estimate change when a system model and noisy measurements offer competing clues? Intuitive Understanding of Kalman Filtering with MATLAB® develops that intuition step by step, then uses simulations and inertial measurement unit (IMU) examples to show the method at work.
Start with uncertainty, not equations
The book lays the groundwork with system models, random variables, probability distributions, Gaussian behavior, covariance, conditional probability, and Bayes’ rule. These foundations give readers a way to understand why a filter combines information rather than simply trusting a prediction or a measurement in isolation.
See how prediction and correction work together
Examples—including an electrical circuit and a falling wad of paper—help connect the general filtering problem to recognizable situations. The discussion then follows the filter’s iterative process: predict a state from a model, compare it with measurement-based information, and refine the estimate during the correction phase.
Explore the algorithm through MATLAB® examples
In the MATLAB® section, the authors demonstrate univariate and multivariate cases, simulated signals, filter variables, and the timing loop. The examples make it possible to examine how model and measurement information contribute to an estimate, rather than treating the algorithm as a formula to memorize.
From sensor signals to attitude estimation
The final part applies the framework to two-axis attitude estimation using IMU signals. It discusses relevant reference-frame and attitude concepts, considers gyroscope and accelerometer information, and presents both prerecorded-signal and real-time implementations.
Who may find this useful
This book is suited to readers who want a conceptual introduction to Kalman filtering with MATLAB-based examples. Students, engineers, and technically minded hobbyists interested in estimation, sensor data, or IMU applications can follow its progression from probability fundamentals to practical demonstrations.
User Reviews
Only logged in customers who have purchased this product may leave a review.
Original price was: $46.75.$23.38Current price is: $23.38.
There are no reviews yet.